Posted in Academic Issues, Geotechnical Engineering, Soil Mechanics

SLOPE Stability Software Program

Ever since this site’s predecessor was started in 1997, one of the things it’s “about” is offering useful documents and software at no charge. With software that’s become more difficult as operating systems have changed and some software has become inoperable on newer computer systems. We’ve gotten around that for DOS and Windows 3.1 applications, as shown in Partying Like It’s 1987: Running WEAP87 and SPILE (and other programs) on DOSBox. In this case we’re featuring a Windows-based, 32-bit software program for slope stability called–wait for it–SLOPE. It was developed by the late Arnold Verruijt, whose Soil Mechanics book I used for many years.

Downloading the Software

That’s pretty straightforward: click on the link below and save the file to your computer.

Download SLOPE Stability Software

What you’ll see is slope.zip. Computers and file download sites are getting nervous about raw Windows .exe files, so all you need to do is to extract the one and only slope.exe file from the archive.

Starting SLOPE

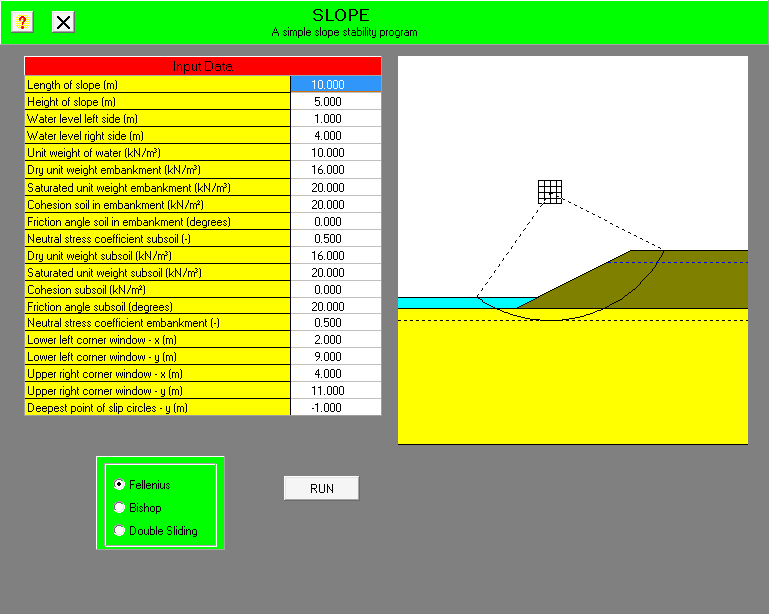
Now we come to the first discovery: slope.exe isn’t a program installation file, it is the program! You just double click on it and you will be greeted with the interface shown at the top of the post. The data entry is in the while column under “Input Data.” We will explain the input in an example.

The Example

The example is shown below, it is taken from the Soils and Foundations Reference Manual. The description from there is as follows:

Figure 6-20 shows a 35 ft high slope with a grade of 1.5H:1V. The soil properties within the slope and under it are shown on the figure. Groundwater is immediately under the slope. Calculate the factor of safety for a toe circle by using total stress analysis based on the soil properties shown.
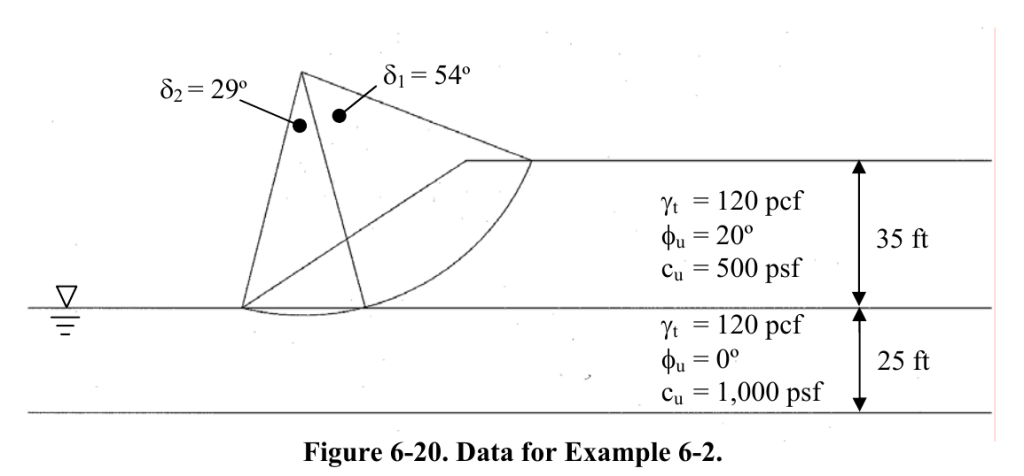
Because slope locates the slip circle of failure, we can ignore the geometry specified in that part of the drawing.

Basic Principle of Operation

SLOPE is based on classical slope stability techniques that goes back to Wolmar Fellenius’ work in the first part of the last century. It assumes that the soil fails along a circular surface, as shown below.
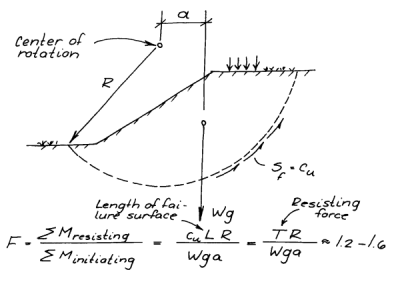
The weight of the soil is driving the soil downward, and this is resisted by the shear resistance along the failure surface (the dashed line.) That resistance is affected by a number of factors, including effective stress along the failure surface, friction of the particles, and cohesion of the soil. The whole mass rotates about the center of rotation, which has to be determined during analysis.

The most common method used–and the one SLOPE uses–is the method of slices. In that method the soil mass is divided into vertical slices, each of which has a mass, some kind of resistance along the failure surface, and (for most of the methods used) how the slices interact with each other.

The theory is described in both Soil Mechanics and the Soils and Foundations Reference Manual. The computations can be laborious, but the really tricky part is determining the location of the center of rotation and the radius R of the failure surface. SLOPE takes care of all of that but it is essential for you to understand how it does that, as its determination of all of these factors is not automatic.

Dealing With Different Expressions of Slope

One common problem with slope stability situations is how the geometry of the slope is defined. There is more than one way of doing it, and the method used in the problem is different than the one used in SLOPE.

The problem states that the slope is 35′ high (the vertical length of the slope) with a grade of 1.5H/1V. This means that, for every foot or meter of height, there are 1.5 feet or meters of horizontal length. In this case the horizontal length is (35)(1.5)/(1) = 52.5′. Alternatively we can compute the angle of slope as arctan(1/1.5) = 33.7 degrees, in which case the length is 35/tan(33.7) = 52.5′

Inputting the Data

SLOPE requires the data to be put in SI units. We will do the conversions as we proceed. The data input is as follows:

  • Length of slope (m) = 52.5′ = 16 m
  • Height of slope (m) = 35′ = 10.7 m
  • Water level left side (m) = 0 (from problem statement, zero is at the toe of the slope)
  • Water level right side (m) = 0 (again from problem statement)
  • Unit weight of water (kN/m3) = 10 (reasonable approximation)
  • Dry unit weight of embankment* (kN/m3) = 120 pcf = 18.9 kN/m3
  • Saturated unit weight of embankment (kN/m3) = 18.9 (in absence of better data, use the same)
  • Cohesion soil in embankment (kN/m2) = 500 pcf = 23.9 kN/m2
  • Friction angle in embankment (degrees) = 20 (from problem statement)
  • Neutral stress coefficient subsoil** = 1.00
  • Dry unit weight subsoil* (kN/m3) = 120 pcf = 18.9 kN/m3
  • Saturated unit weight subsoil (kN/m3) = 18.9 (in absence of better data, use the same)
  • Cohesion soil subsoil (kN/m2) = 1,000 pcf = 47.9 kN/m2
  • Friction angle subsoil (degrees) = 0 (from problem statement)
  • Neutral stress coefficient embankment** = 0.66
  • Lower left corner window*** – x(m)
  • Lower left corner window*** – y(m)
  • Upper right corner window*** – x(m)
  • Upper right corner window*** – y(m)
  • Deepest point of slip circles – y(m) = -25′ = -7.6 m (this is negative as it is below the toe of the slope)

Notes:
* The embankment is above the toe. The subsoil is below it.
** The neutral stress coefficient is more commonly referred to in American practice as the at-rest earth pressure coefficients. For normally consolidated soils, it equals to 1 - \sin(\phi) , and the results are shown in the input list. The entry points for both are out of order, so be careful.
*** This will be explained below.

Choosing the Window Points and the Method of Analyzing the Slices

If we put all of this data into SLOPE, we get the following result:
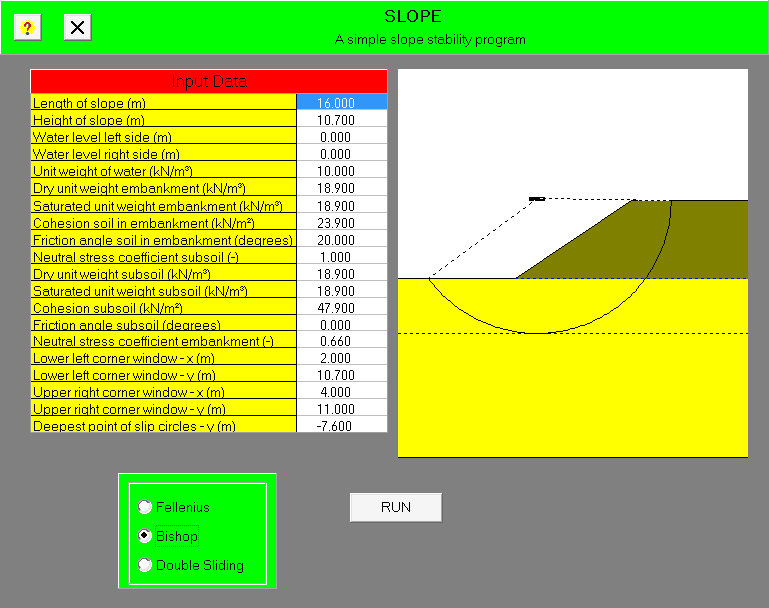
Before we get some results, we have to make two decisions: what slice analysis method to use and the extent of the window.

Soil Mechanics gives an explanation of Fellenius and Bishop’s methods. SLOPE divides the region in the slip circle into the horizontal slices; the difference between these two methods is that Fellenius’ method does not consider friction between the slices while Bishop’s does. Fellenius’ method does not require an iterative solution and is the most conservative; however, given that the computational effort is done by the program, we will use Bishop’s method, which is in common use.

As far as the “window” is concerned, SLOPE, in common with many slope stability programs, uses a grid optimization method to find the location of the rotational centre. This means that a set of points in a regular grid are each analyzed (along with appropriate slip circles) to get the factor of safety (see sketch above) and after analyzing all of these points picks the one with the lowest factor of safety. It’s easy to see that, using the original grid, not much in the way of useful information can be found as the selection of grid points is too small. For a grid point to be valid, it has to be in the interior of the window, not at the edge, because if it’s at the edge it’s possible that the point will be outside of the window.

The window limits are set using a coordinate system with the origin at the toe of the slope. Generally the slip circle centre will be above and to the left of the upper corner of the slope. Values for y should not be less than the slope height and values for x should be greater than zero and less than the length of the slope.

Getting an acceptable result is an iterative process. Let us assume the following for the window boundaries:

  • Lower left corner window*** – x(m) = 2 m
  • Lower left corner window*** – y(m) – 10.7 m
  • Upper right corner window*** – x(m) – 14 m
  • Upper right corner window*** – y(m) – 15 m

If we apply these and then Bishop’s method for the analysis, we get the following result:
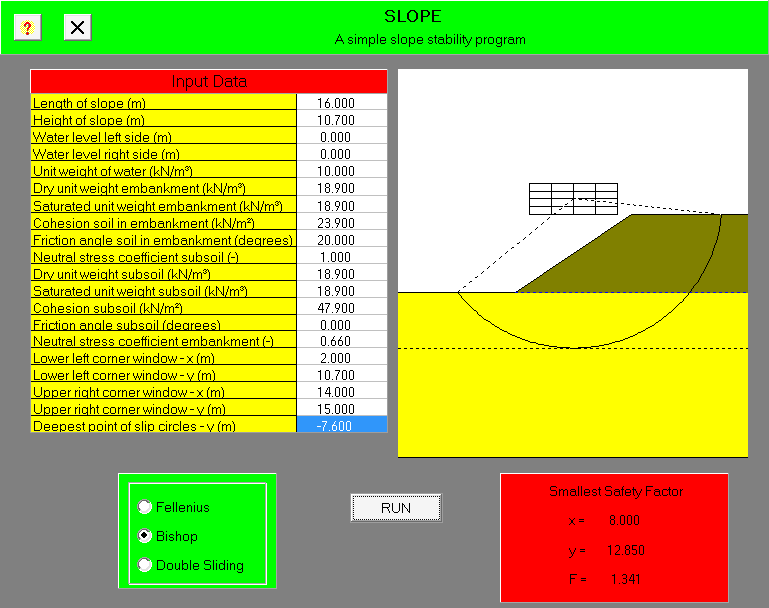
We can see the slip circle centre is in the interior of the grid. If we desire we can shrink the window to get a finer grid and a more precise result.

Sometimes assuming the slip circle going to its lowest point does not result in the lowest factor of safety. To simulate something close to a toe circle, let us set the deepest point at the bottom of the embankment; the result we obtain is as follows:
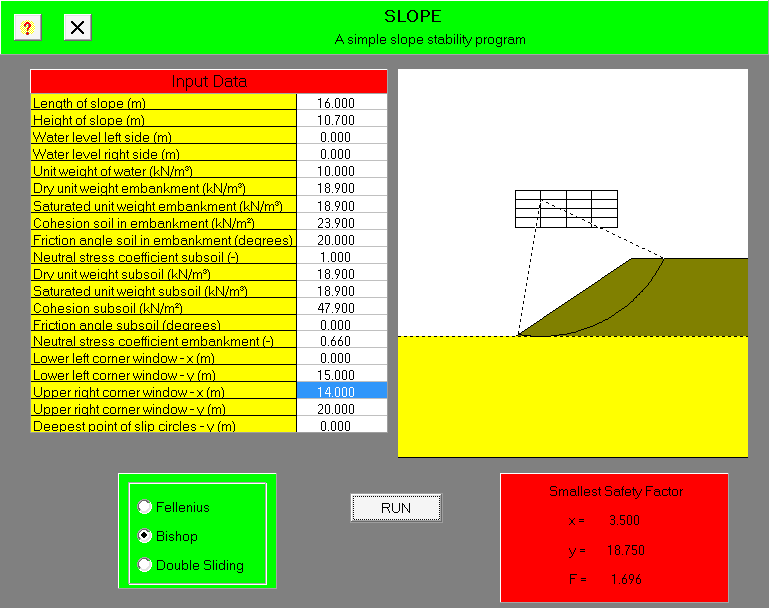
In this case (with some adjustments to the window) the factor of safety is still higher for our original case.

Reporting the Results

SLOPE is not installed, and as a result does not print out its results. The only way to save the results from the program is to get them off of the screen. This is fairly straightforward: use a grab or screenshot program, which was done with the images in this post. Unfortunately many of my students, for whatever reason, insisted on using their phones to take shots of the literal screen, which generally look awful. This was the technology I used forty years ago when presenting this program; we’ve come a long way since.

Conclusion

SLOPE is a fairly simple program to use. It lacks many of the automation and stratigraphy defining features other slope stability software packages have, and is not suited for use in practice. For academic use, however, it is good, and gets students past one of the most tedious features of geotechnical computation.
Posted in Geotechnical Engineering, Soil Mechanics

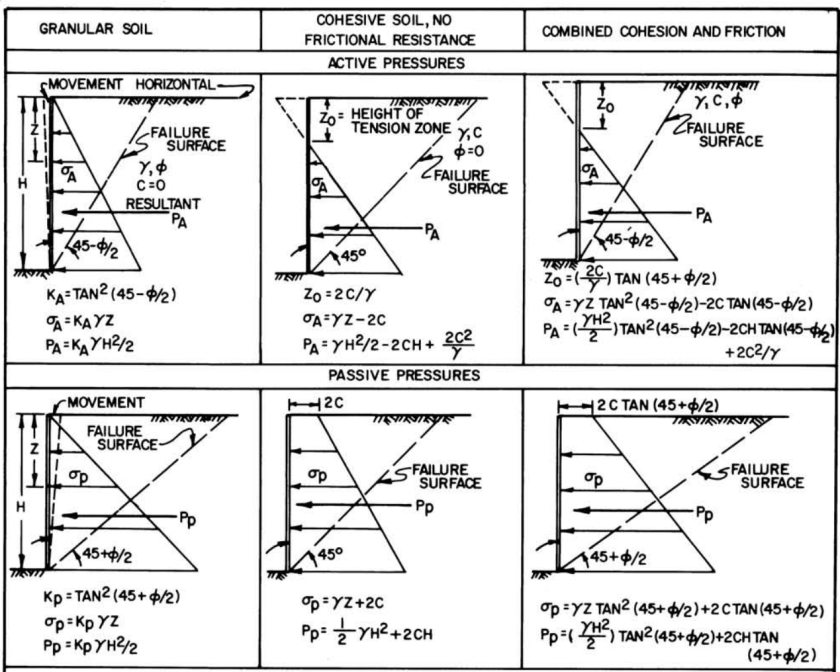
Why Only Rankine?

With release of Soils in Construction, Seventh Edition, we now turn to discuss some of the special topics surrounding this book. One of them is the earth pressure theory we adopted: Rankine earth pressures, level backfill, with provision (when necessary) for cohesive soils. For a textbook this seems awfully restrictive, but there are justifications for this policy.

Rankine earth pressure theory is the most elementary of the earth pressure theories. It is customary, however, in introductory geotechnical courses such as Soil Mechanics and Foundation Design and Analysis, to present all three failure criteria (Rankine, Coulomb and Log-Spiral.) For many years I did so in the first course and went back to expand on that in the second; it was the only topic I formally reviewed from one semester to the next. In spite of that, my students found the topic confusing, never sure which theory applied even when I made it clear (or so I thought.) What I ended up doing was teaching strictly Rankine theory in Soil Mechanics and the others in Foundation Design and Analysis.

Rankine is also characterised as the most conservative of the earth pressure theories. In his response to a paper by Terzaghi (reviewed for other reasons in my post An Industry Gets Restless: Terzaghi’s 1929 Paper on Dynamic Formulae and the Response) Lazarus White made the following observation:

In the Nineties, when the writer was an undergraduate student, he was thoroughly imbued with the classical methods of computing earth pressures, bearing values of soil, distribution of pressures, and pile-driving formula commonly taught–Rankine, Baker, Cain and Wellington–and, after his graduation, he set about to apply them…Later, during subway construction, he observed that contractors completely and successfully ignored Rankine and Cain in timbering work, and “got away with it” in so many instances that by no scientific philosophy could their theories be justified.

Of the four methods he mentions, only Rankine is still taught as a “currently” used method, although it too is being displaced by methods such as FEA. So how can the decision to teach only Rankine in Soils in Construction be justified? It is done as follows:

  • It’s good that White’s result was “got away with it” and not a collapsed wall; retaining wall failures tend to be catastrophic. It kept his work out of trouble until better methods could be employed.
  • It was the policy of previous editions of the book, although some attempt has been made to use Rankine in conjunction with Mohr-Coulomb for a theoretically consistent presentation.
  • Soils in Construction is primarily aimed at giving contractors a better understanding of geotechnical issues, not as a design guide. It can be taught in a more geotechnical engineering way but its first task is contractor education.
  • Some introductory geotechnical courses only teach Rankine theory with level backfill, such as Tsytovich, which came as something of a shock to me. Either proficiency in more advanced theories were left to experience or later courses for specialists.
  • As noted and in common with NAVFAC DM 7.2, only level backfill is considered, as discussed in my post NAVFAC DM 7.2: Analysis of Walls and Retaining Structures, Part I: Will the Real Rankine Theory Please Stand Up?. Rankine theory can be extended to sloping backfills but again we did not feel this was necessary for a book such as Soils in Construction.
  • Rankine theory with level backfill is the only theory necessary to take the FE exam; preparation for this was one of the objectives of the “extended” material in the book.

Posted in Civil Engineering, Soil Mechanics

Location of Corner of Failure Envelope for Anchored Sheet Pile Walls

A recent inquiry revealed that the literature on this site and vulcanhammer.info has a difference of design procedure for anchored sheet pile walls.

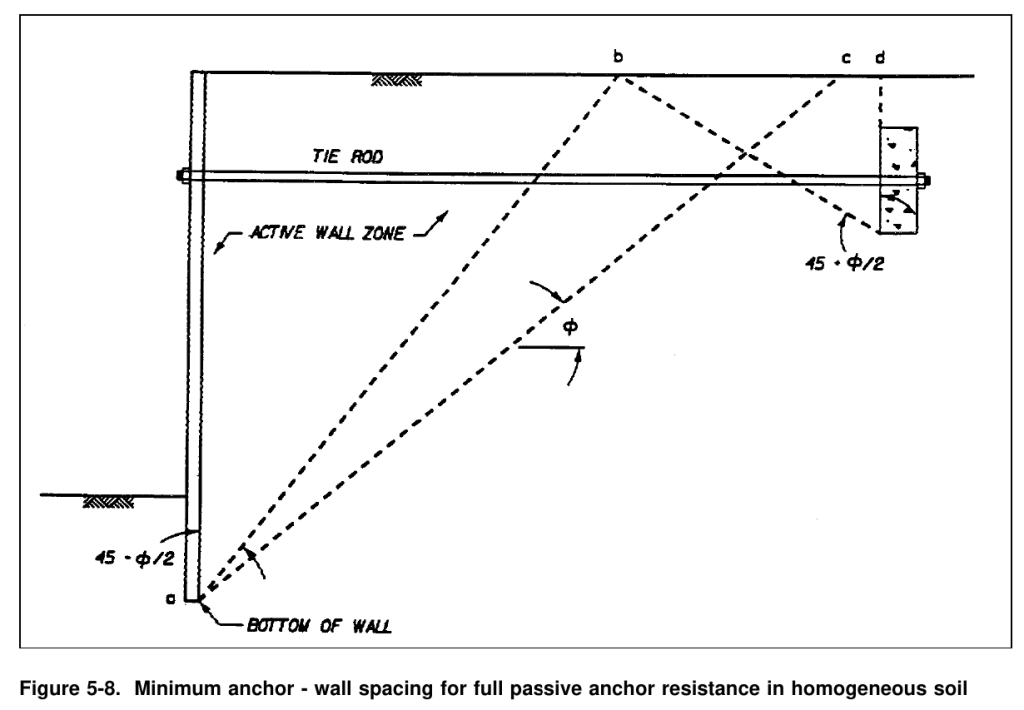
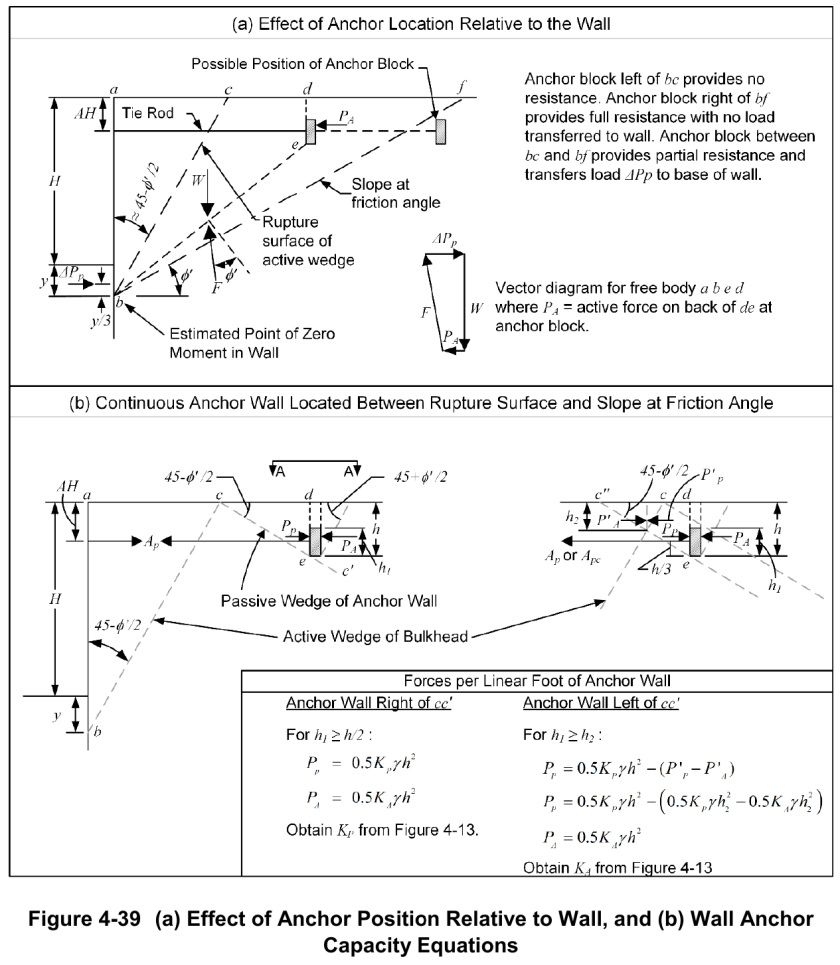
In order for a deadman anchor to be effective, it must be beyond the failure envelope. Here we present two ways to insure that this is so.

The first is shown above: it is taken from NAVFAC DM 7.2, although it has been in many publications over the years, including NAVFAC DM 7.02 and Sheet Pile Design by Pile Buck. It shows the point at which the failure envelope starts as the “estimated point of zero moment in wall.” That can be determined using software such as SPW 911.

The second is shown below, from EM 1110-2-2504, and shows the same point at the bottom of the wall.

If you have any comments about either of these methods, or which one you prefer and why, let us know in the comments.

Posted in Deep Foundations, Soil Mechanics

Comments on “Using the Impulse-Response Pile Data for Soil Characterization”

This is another post on a paper (linked to from here) which cites my work, in this case two of them: Improved Methods for Forward and Inverse Solution of the Wave Equation for Piles and Closed Form Solution of the Wave Equation for Piles. The concept is simple but the execution, not so much, and as with anything with geotechnical engineering there are pitfalls on the way to a usable solution.

We start with an existing technology: low-strain integrity testing of piles. A simple example of this is shown above, it’s the Pilewave program from Piletest. (Yes, I’m aware that it’s the Windows 3.1 version, if you’re interesting in running DOS and Windows 3.1 programs to save on the expense of “new” engineering software, you can visit Partying Like It’s 1987: Running WEAP87 and SPILE (and other programs) on DOSBox.)

With that distraction out of the way, note that, as the stress wave goes down and back up the pile, there is attenuation due to the interaction with the soil. In the simple demo of Pilewave, the soil resistance is constant along the shaft. But…if we could determine that the pile didn’t have defects which reflected waves, could we use information from the soil attenuation to determine the type of soil surrounding the pile at any given elevation? The answer in principle is “yes” and this paper, although not unique, it is an interesting step forward.

Pile Integrity Testing is a low-strain technique. That’s in contrast to the high-strain methods we’re used to in pile driving analysis. This one takes a leaf from the seismic refraction method (which will be featured as before in Soils in Construction, Seventh Edition) which is also a low-strain technique, as it is a geophysical method. The idea is that the pile acts as a probe into the soil; the response to exitation can be inversely analysed to determine the types of soils around the pile. As the paper notes, if you divide up the pile into enough “layers” the actual soil layering itself (based on the properties returned to you by the method) will basically emerge from the data.

As is generally the case with inverse methods, the solution is complex; it is described in the paper. There are a few comments that I would like to make as follows:

I hope that this research continues; I think it has potential.

Posted in Civil Engineering, Soil Mechanics

New Year, New Prices: Geotechnical Books Update

As we begin a new year (for this site, it’s the 29th) we need to clarify some things that have changed regarding our book offerings.

We’ve been with Lulu publishers since 2006 (this is our twentieth year with them) and we’ve been through many changes in the publishing industry since that time. In those days we not only offered print books (our government doesn’t print their geotechnical publications any more) but also CD’s with documents. They only sold these books and CD’s on their own website.

Later they began to offer to put books “in distribution,” i.e. with places such as Amazon.com and other book sellers. We’ve been migrating our product line in that direction but have run into two problems.

The first is that distribution is expensive; these people like to take a substantial cut. This forced us to price things accordingly, although we’ve tried to keep our own cut at a reasonable level.

The second is that the requirements for a book to be in distribution changes, or more accurately the way that Lulu and these publishers enforce these requirements changes. The result is that books which have been in distribution for years are no longer there, although they’re still available from Lulu.

Our response to this is to simply keep the books in distribution which are most popular and to allow the rest still being published to stay on Lulu. The result of that is below, with our entire geotechnical book line listed. In taking books out of distribution we’ve looked at our pricing and have reduced prices on several titles.

We’d like to wish everyone who visits this site a Happy and Prosperous New Year.

Geotechnical Books Which Are in Distribution

Geotechnical Books Which Can Only be Obtained From the Publisher

Our other books are available at our sister web site Chet Aero Marine.